NI-SLAM is an efficient SLAM (Simultaneous Localisation and Mapping) approach that rapidly estimates position and maps the environment, benefiting autonomous systems like vehicles and robots.
Real-time pose estimation and mapping. Closed-form solution (no repeated optimisation loops)
Reduced processing complexity, works on both high and low compute platforms. Suitable for embedded systems
Uses RGB-D cameras and depth scanners, integrates inertial sensor data and builds dense 3D maps
Autonomous vehicles, drones and robots, augmented and mixed reality, indoor navigation and logistics, construction and disaster response
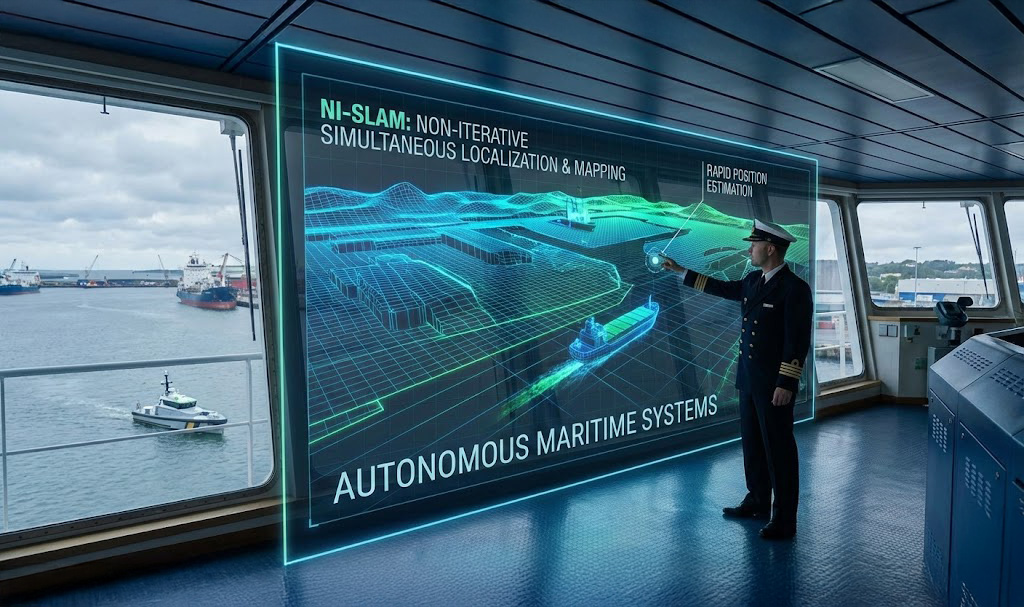
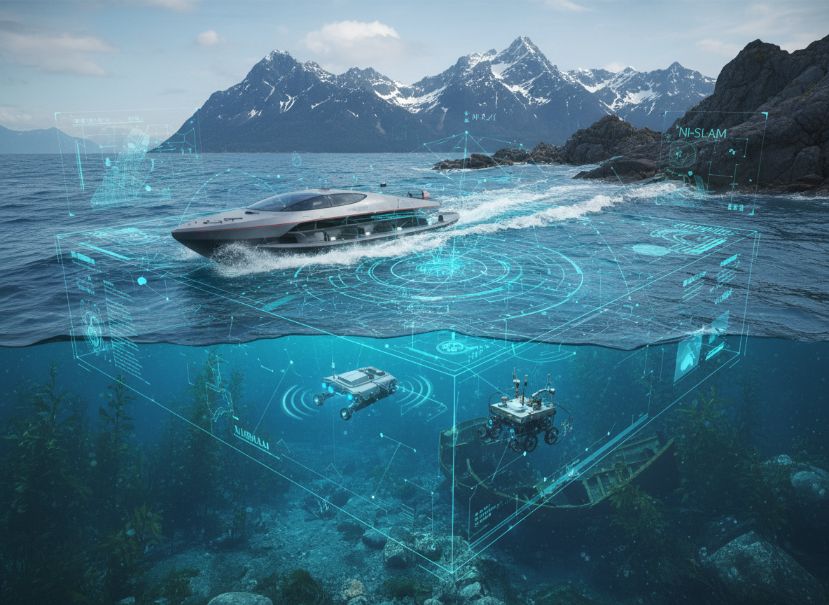
The NI-SLAM (Nonlinear Inverse SLAM) technology could be adapted to enhance the navigation and mapping capabilities of autonomous maritime vehicles, such as USVs, AUVs, and ROVs, enabling them to operate more reliably and effectively in complex maritime environments.
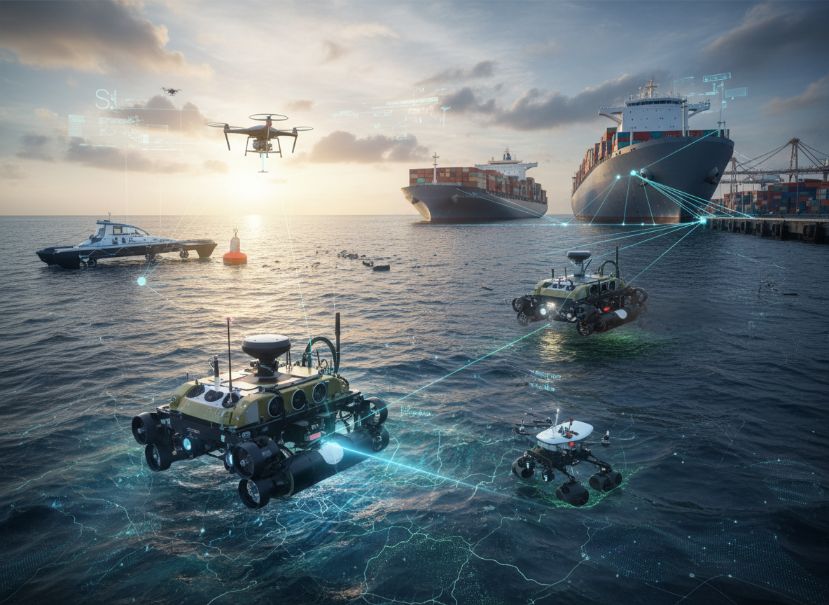
The improved SLAM performance could support a wide range of maritime applications, including hydrographic surveys, underwater inspections, environmental monitoring, search and rescue operations, and autonomous cargo handling or berthing maneuvers.
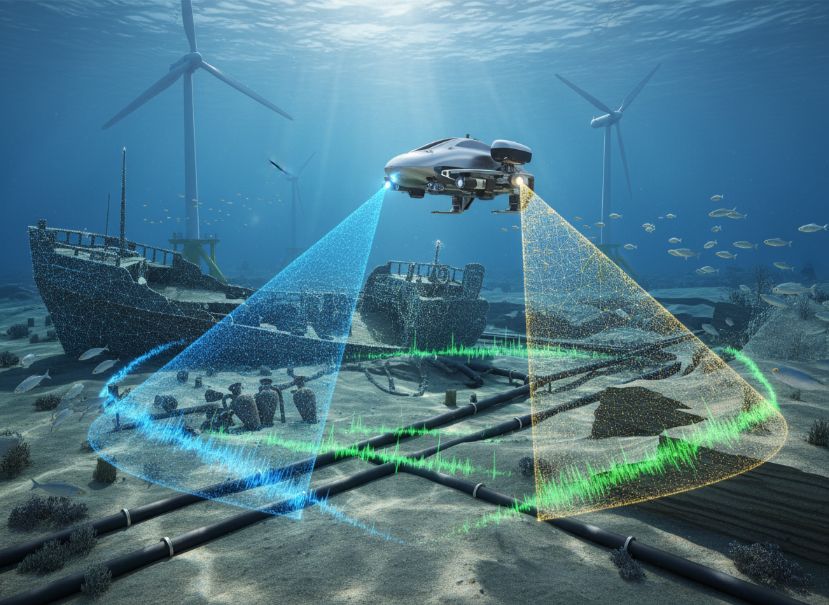
The improved SLAM performance could support a wide range of maritime applications, including hydrographic surveys, underwater inspections, environmental monitoring, search and rescue operations, and autonomous cargo handling or berthing maneuvers.
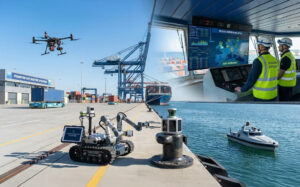
In addition to being one of the busiest ports in the world, Singapore has also likewise thrived as one of the leading global maritime capitals that is highly driven by knowledge-based services and expertise. With changing demands and complexity of port and shipping activities, there would be a need for better management of complex port and ship systems.
With global trend drivers, such as shipping market volatility, environmental regulations, and energy cost-efficiency, advanced technological solutions would be required to address these concerns through innovation in port infrastructure and ship design. Hydrodynamics, physical modelling, and mathematical modelling are some of the scientific means towards more cost-effective and environmentally friendly operations. There has also been proposed methodology that focuses more on integrated systems-approach over independent components-approach.
An integrated systems strategy would also drive the need to manage sophisticated engineering and technology through risk-based approach for higher reliability and asset lifecycle management to bring cost benefits. This would enable users to complement both business and technical objectives.
Building upon the above technological trend towards a greater need for advanced complex systems, higher end training would also be required to produce competent manpower with the critical domain knowledge and skillsets. Looking beyond the conventional field of training through simulation, research in the human-machine interface through applied human engineering studies of maritime ergonomics would also be applicable to optimise interaction between people and technology for safety and productivity best practices.
As part of Singapore Maritime Institute’s (SMI) efforts to support the maritime industry in Singapore, a research grant amounting to S$5 million has been allocated to promote research through this thematic R&D programme. The Simulation & Modelling (SAM) R&D Programme aims to support projects involving the research and development of innovative technologies, approaches and ideas towards simulation & modelling for maritime applications.
Programme Themes
In oil & gas E&P, safe and reliable operations are of paramount importance to the industry. Asset integrity should never be compromised and risk management is critical to ensure lives and marine environment are safeguarded.
With enhanced oil recovery techniques, operators are stretching the existing reserves with assets that are reaching their design service life. These aged assets are often susceptible to failures due to mechanical degradations and harsh offshore environment.
Oil exploration has also inevitably moved into deep-sea as shallower oil wells become depleted. The offshore assets are installed in deeper water and are increasingly inaccessible. The associated cost of asset maintenance increases exponentially for deep-water regions resulting in the need for technological innovations in asset integrity & risk management. Integrity assessment and risk management solutions, anticipation of possible failures of systems and emergency response plans in the event of asset failures would be critical.
The offshore assets covered include offshore structures, subsea and down-hole equipment. The key research objectives are:
a) Identification of safety critical elements (SCEs)
The weakest structural components that are most susceptible to external forces, cyclic loadings and harsh environment known as safety critical elements should be identified.
b) Reduction of reliance on manual inspection
The inaccessible assets in deeper water and harsher environment drive the need for remote and autonomous inspection and maintenance which are increasingly reliant on sensor based technologies.
c) Low hardware overheads
Cost is one of the major considerations when sensors and wireless systems are installed. Such overheads include the cost of manufacturing the sensors and systems, power requirement as well installation compatibility with the existing assets.
d) High reliability systems under harsh environment
The increasingly harsh environment at deeper water with strong waves and currents as well as deeper wells with hostile chemicals and high pressure high temperature (HPHT) pose significant technical challenges. Sensors and systems must survive such environment with high reliability.
Programme Themes
Projects awarded (will be updated progressely):
Maritime Research between Norway and Singapore (MNS)
Maritime navigation safety
Ship operation & safety
Green shipping
Ship-port operations
Oil and gas exploration and production (E&P) has inevitably moved into harsher operating environment. While oil price has slumped to a very low level, industry is focusing on technology developments to lower the cost of E&P. The fundamental sciences such as chemistry, physics and materials have attracted more attention than before in seeking innovative and disruptive technologies to enhance operational efficiency and improve reliability.
Operations in deeper waters with strong waves and currents pose challenges on structural integrity. Operations in Arctic pose a different set of challenges with extreme low temperature. As industry moves into ultra-deep wells with extreme high pressure and high temperature (HPHT), higher reliability is required in meeting the performance specifications to ensure safe and reliable operations. The underpinning material sciences in different operating regimes are the fundamental challenges to the increasingly harsh E&P environment.
Industry is also constantly innovating new materials for offshore applications as well as smart materials which allow more perimeters to be measured for condition monitoring of offshore structures and processes.
SMI through its engagements with the industry and academia has identified the following research thrusts and corresponding research focus areas under the grant call. The materials covered in this grant call should be used in offshore structures, subsea and down-hole equipment with the following key research objectives:
Given its location at the crossroad between East and West trade, Singapore is one of the busiest ports in the world for commercial shipping and maritime services. Last year, the Port of Singapore welcomed more than 135,000 vessels and handled a total of 560 million tonnes of cargo. The maritime industry is an important part of Singapore’s economy as it is one of the fastest growing economic sectors, contributing to 7% of Singapore’s GDP.
To address one of the key challenges facing the maritime industry on sustainable shipping, research and development into innovative technologies to transform maritime transportation and port operations will enhance both regulatory compliance and better service offerings by the industry.
SMI through its engagements with the industry and academia has identified the following research areas and possible corresponding research topics under the Maritime Sustainability grant call to support maritime developments and environment protection:
a) Ballast Water Management
Possible Research Topics include Detection and Measuring Equipment / Treatment System, Treatment Technology, and Risk Assessment for Ballast Water Management System.
b) Exhaust Emission Control
Possible Research Topics include Scrubbing / Cleaning Technology, Tools and Systems.
c) Ship Noise & Vibration
Possible Research Topics include Simulation & Modelling, Materials, and Ship Design and Construction.
d) Port Sustainability
Possible Research Topics include Port Air Emission Control Technology, Cleaner Energy for Port, Port Waste-to-Resource Management, and Energy Conservation.
The Maritime and Port Authority of Singapore (MPA) and the Singapore Maritime Institute (SMI) have awarded funding to three consortiums led by Keppel FELS Limited, SeaTech Solutions and Sembcorp Marine, and comprising a total of 30 enterprises and research institutions, to research, design, build and operate a fully electric harbourcraft over the next five years. These electrification pilot projects will demonstrate both commercial and technical viability of specific use cases for full electric harbourcraft and will support Singapore’s broader plans to mitigate greenhouse gas (GHG) emissions by the maritime transport sector.
Harbourcraft Electrification Projects
| No | Consortium lead | Consortium members | Project Scope |
| 1 | Keppel FELS Limited |
Industry
(Vessel owner/operator)
IHLs/ research institutes
|
To develop Solid State Transformer based shore charger & electric kit on an existing 30 pax ferry |
| 2 | SeaTech Solutions International (S) Pte Ltd |
Industry
(Vessel owner) IHLs/ research institutes
|
To develop a full electric lighter craft[i] |
| 3 | Sembcorp Marine Integrated Yard Pte Ltd |
Industry
(Vessel Owner/ operator)
IHLs/ research institutes
|
To develop and build a full electric ferry for 200 persons for a specific route |
 Vessel Performance & Navigation
 Autonomy & Sensing